Hold position
Maintain a deliberate sensor pose instead of circling back for another pass.
 Partner with us
Patented vectored propulsion
Patented JETTE™ Propulsion Technology equips proven torpedo-form AUVs with advanced three-dimensional maneuverability and hover capability through a modular upgrade package.
01 Patent-protected architecture
02 Dual in-line assemblies
03 Modular upgrade package
04 Multi-class vehicle integration
PLATFORM SCALE / VEHICLE CLASSES
Modular integration paths for proven torpedo-form AUV platforms, from A-Class systems through larger hull-diameter ranges.
The mission changed.
AUV software can plan a perfect mission. Conventional propulsion still limits what the vehicle can physically do when the mission demands more than forward travel.
Fixed control surfaces and exposed propellers are optimized for forward survey lines, not precise movement at zero forward speed. JETTE™ Propulsion Technology closes the gap between the autonomy stack and the ocean.
Two assemblies. One new mission envelope.
Water is managed through fore-and-aft assemblies that work independently and in concert. This generates controlled thrust without relying on a forest of breakable exposed appendages.
Maintain a deliberate sensor pose instead of circling back for another pass.
Translate across a target or structure without needing forward speed to steer.
Move vertically while maintaining heading and sensor orientation.
Rotate at zero forward speed and reacquire the mission line with precision.
Efficient transit and wide-area data collection in a streamlined torpedo form.
Stop, hold station and maneuver with precision around structures and the seabed.
Match and counter a moving contact in three dimensions, giving autonomy the control authority to shadow, bracket and corral an adversary.
A redundant fore-and-aft architecture creates an alternate path home after a propulsion event.
Movement becomes behavior.
JETTE™ adds control authority at zero forward speed. That lets autonomy hold a sensor pose, react to changing conditions and move deliberately around a target instead of repeatedly passing it.
Conventional torpedo-form AUVs steer most effectively while moving forward. JETTE™ can hover, translate, move vertically, pivot through 360 degrees and orbit a point with the bow held inward, keeping sensors trained on the subject throughout the maneuver.
Hover, translate, ascend, descend, rotate through 360 degrees, then orbit an inspection point with the bow trained inward.
Vectored thrust gives the autonomy stack the physical authority to match a contact in three dimensions, preserve a chosen relative position and respond as the contact changes course. The behavior can support shadowing, bracketing and controlled corral maneuvers without a wide turning loop.
The AUV matches movement in three dimensions, holds relative position and closes the available maneuvering space.
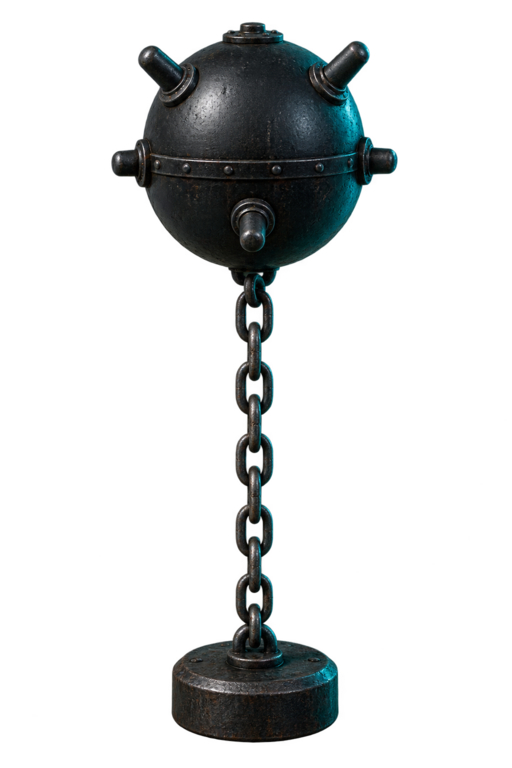
The vehicle transits efficiently in a conventional survey pattern until sonar identifies a potential threat. It then stops, hovers, closes for inspection, circles the object with a stable sensor view, issues an alert and ascends vertically to communicate the finding.
Survey with sonar, classify the moored mine, hover, circle for bow-on inspection, issue an alert and ascend vertically to report.
Modernize the mobility. Preserve the platform.
JETTE™ Propulsion Technology can be delivered as a modular upgrade package for proven third-party AUV platforms. It preserves payload investment, opens higher-value mission profiles and creates a direct path into next-generation vehicle designs.
Defense accelerates the technology. A proven system expands the capability of the wider installed fleet.
Precision mobility for seabed security, mine countermeasures, port surveillance and autonomous move-countermove operations in complex water.
Controlled, close-proximity survey around subsea cables, pipelines, landing zones and high-value maritime assets.
Repeatable inspection around wind foundations, inter-array cables and offshore production infrastructure.
Stable, deliberate observation for environmental monitoring, hydrography, research and deep-ocean discovery.
The next strategic frontier is underwater.
Tiburon Subsea brings together ocean operators, vehicle engineers and defense-market leaders to solve the mobility constraint at the center of underwater autonomy.
Founded by ocean explorer Tim Taylor, the company is building the propulsion technology that lets autonomous systems perform where the mission actually happens, not just pass over it.
OEMs · Primes · Program offices · Operators
Talk with Tiburon about vehicle integration, mission requirements, strategic partnerships and the path to the water.
Start a conversation